| LinkedIn |
GitHub | |
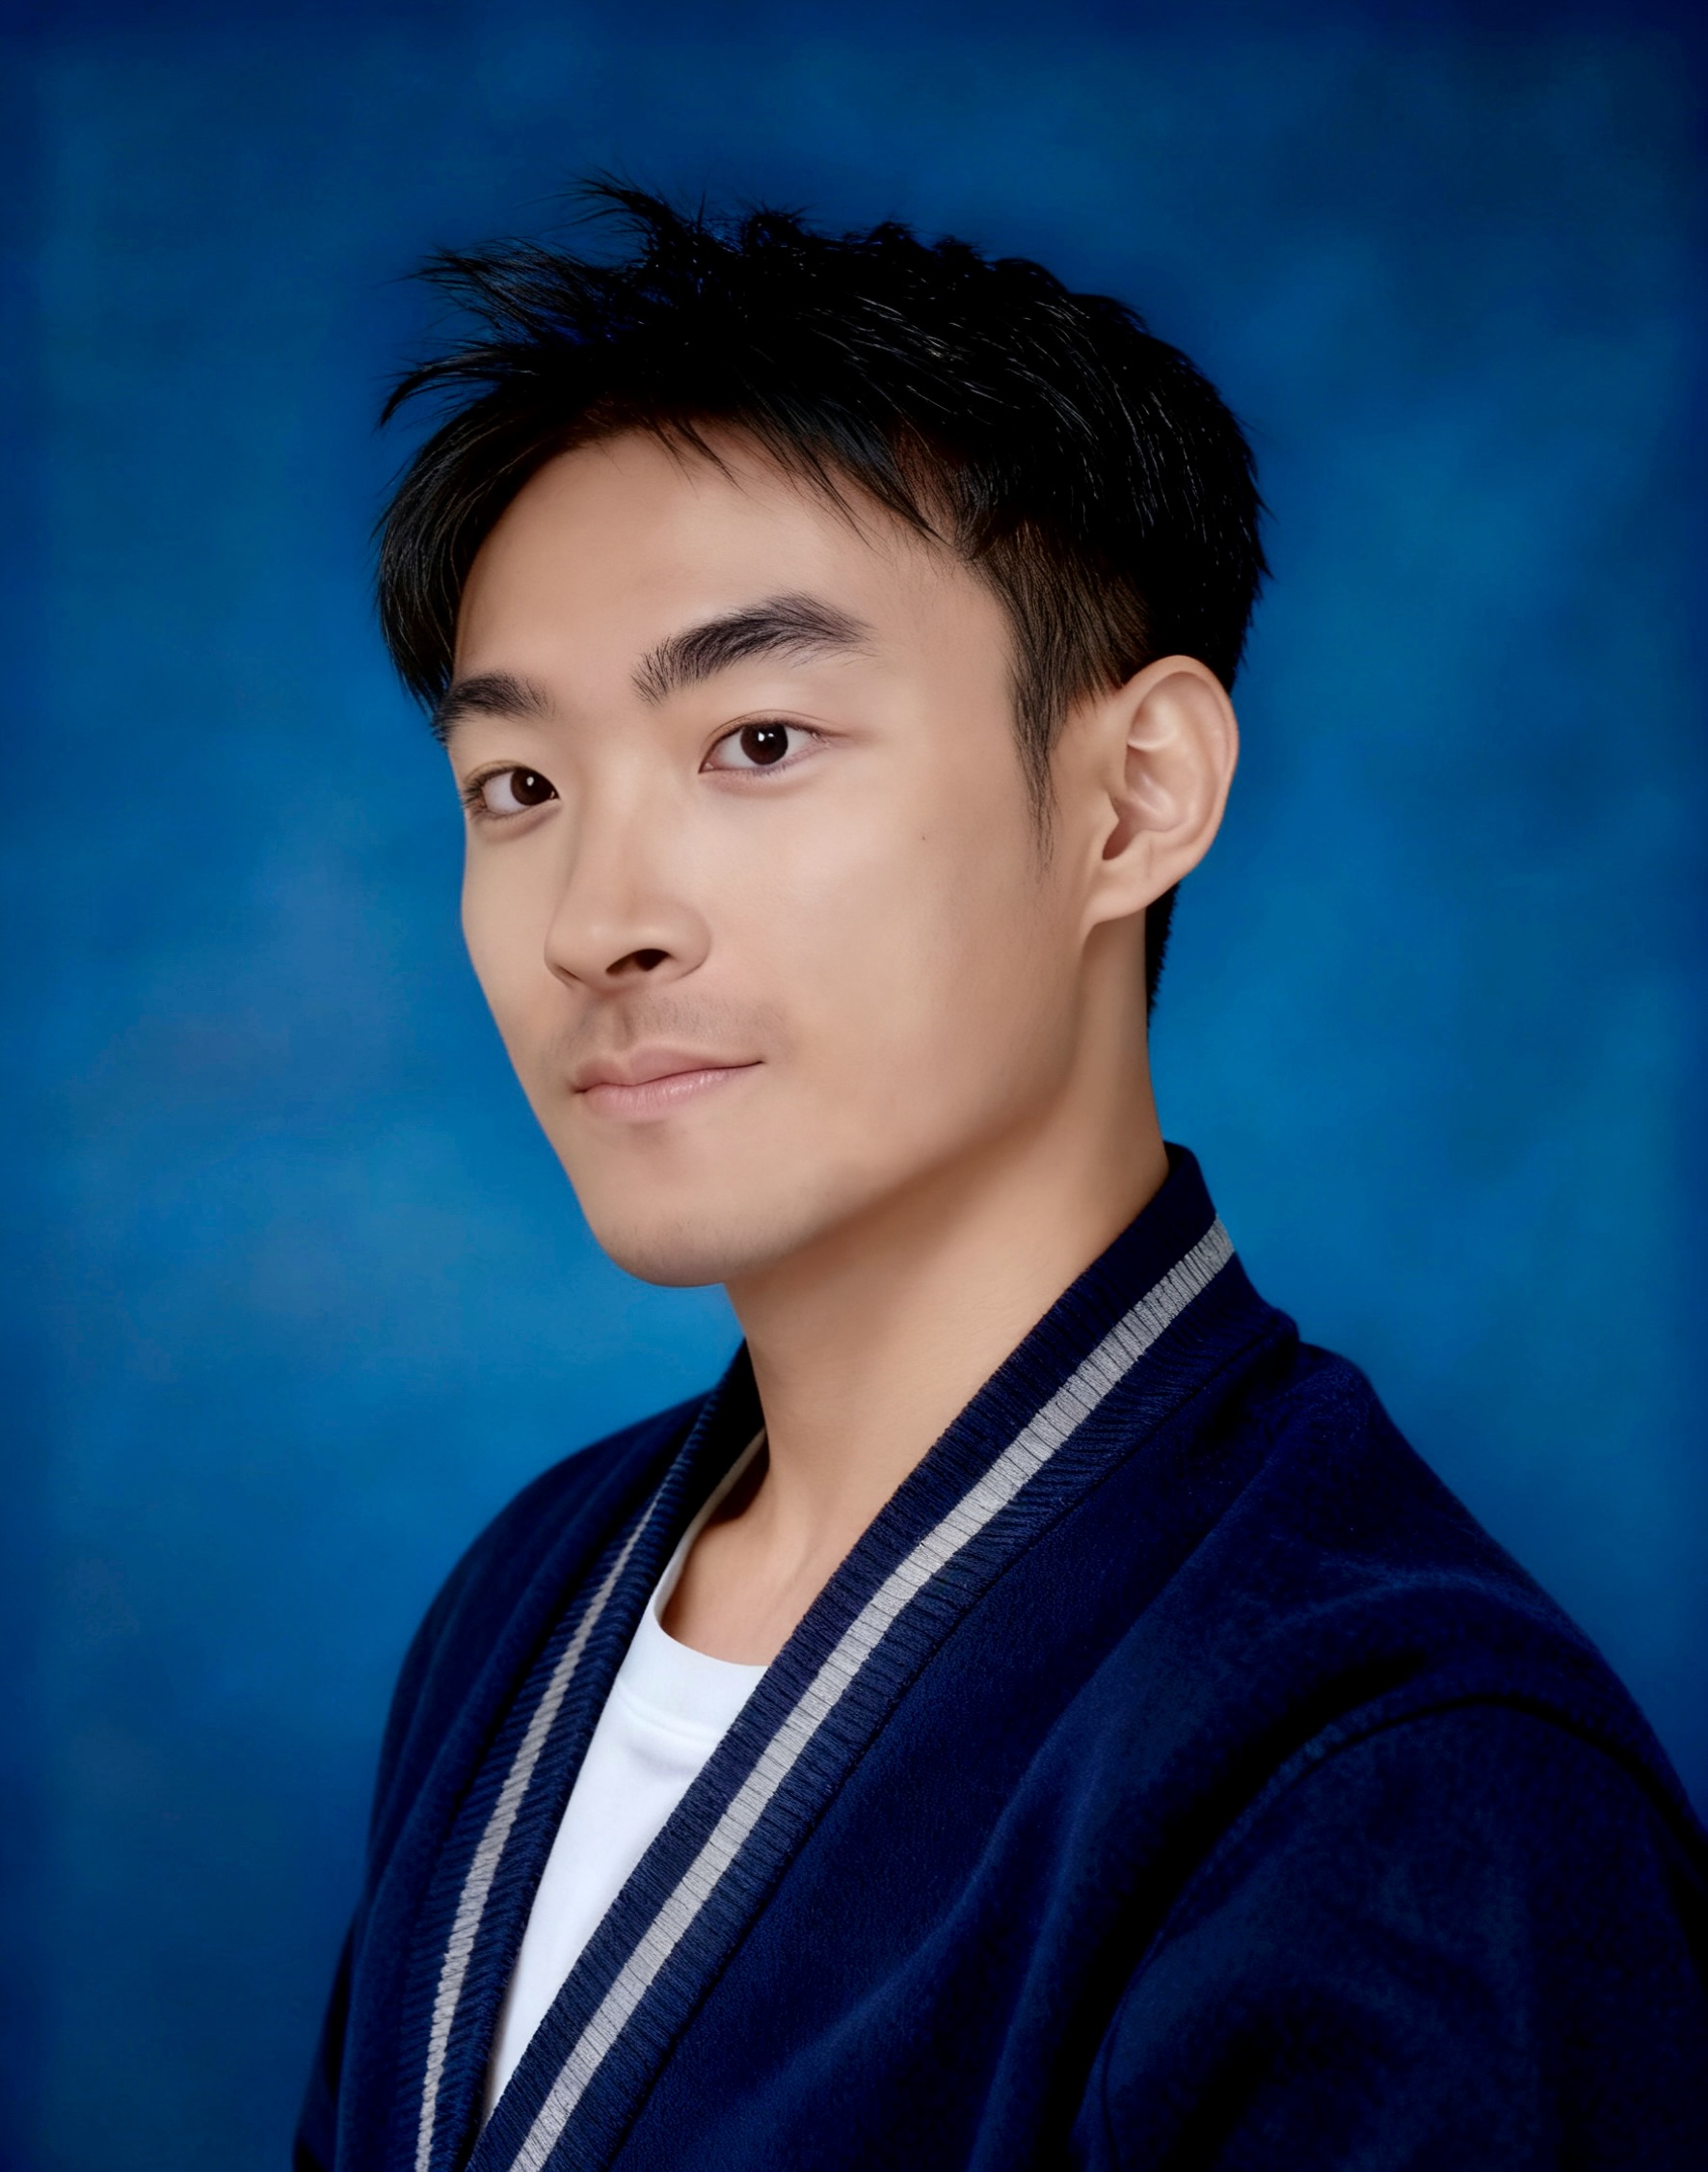
Jiawei Xia 「夏佳炜」 I am a master's student at the University of California, Berkeley. My research focuses on Robotics and AI. Currently, I am a research assistant at Berkeley BAIR. Before that, I received my B.Eng. from Beijing University of Chemical Technology. Previously, I worked as a research intern at the Institute for AI Industry Research, Tsinghua University and an embodied AI algorithm intern at JD Explore Academy. I enjoyed my time at both institutions. I also enjoy photography, Formula 1, and basketball. You can see my photographs here! Email: xiaarrold [AT] berkeley.edu |
News
|

Education |
|
University of California, Berkeley, USA
Master of Mechanical Engineering (Robotics) 2026.8 - Present |
|
Beijing University of Chemical Technology, Beijing, China
Bachelor of Engineering, Mechanical Design and Its Automation (Robotics) 2022.9 - 2026.6 GPA: 3.71/4.33 Rank: Top 5% Former President of SIE Robotics Club. |
| Show more |
Research Experience |
|
Berkeley Artificial Intelligence Research (BAIR) Lab
Research Assistant | Aug 2026 – Present Faculty Advisors: Prof. Koushil Sreenath and Prof. Masayoshi Tomizuka Direct Mentors: Dr. Ruihai Wu and Haoyi Niu My research focuses on skill learning for robotic dexterous manipulation and policy post-training with reinforcement learning. |
|
JD Explore Academy, JD.com, Inc
Embodied AI Algorithm Intern | Mar 2026 – Jun 2026 Mentors: Dr. Lvsong Li and Dr. Jiangmiao Pang Conducted research on 3D/4D world models and vision-language-action models for embodied AI. |
|
Institute for AI Industry Research, Tsinghua University
Research Intern | Dec 2024 – Feb 2026 Advisors: Dr. Yongliang Shi and Dr. Weining Lu Developed LiDAR–inertial–visual SLAM methods and explored tactile sensing and thermal imaging for robot learning. |
| Show more |
Publications* : Equal contribution; †: Corresponding author(s) |
|
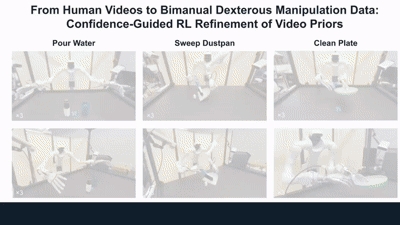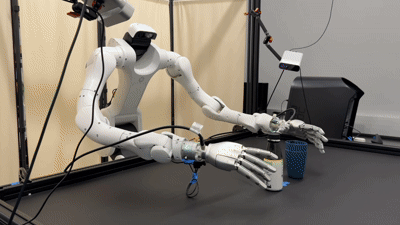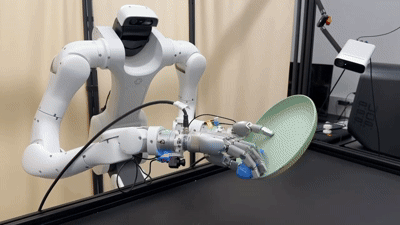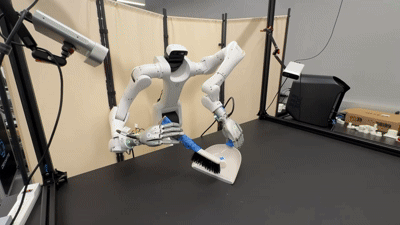
Learning Robot Dexterous Manipulation from Low-Quality Ego Video
Under Review [Paper] [Website] We propose a framework that uses reinforcement learning in simulation to transform low-quality human-video priors into executable robot demonstrations. We evaluate our approach on four bimanual dexterous manipulation tasks using Dexmate dual arms and Sharpa dexterous hands. |
|
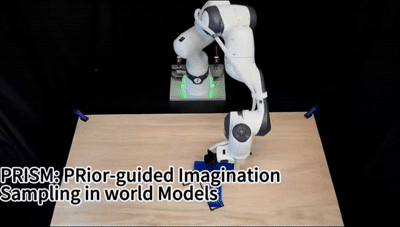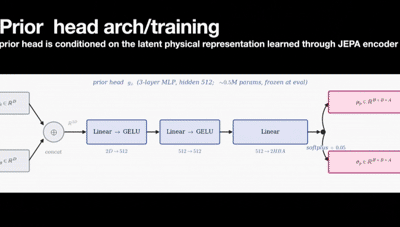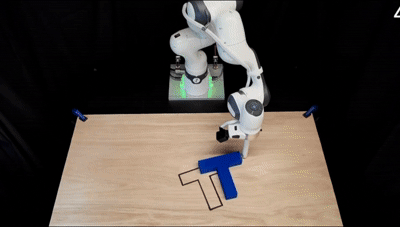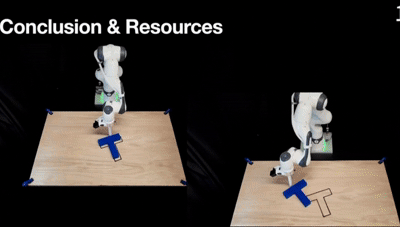
PRISM: PRior-guided Imagination Sampling in world Models
Yuhai Wang, Jiawei Xia, Rongxuan Zhou, Hu Xiao, Yongliang Shi, Du Jing, Yang Ye† Under Review [Paper] [Website] We introduce PRISM, a simple, task-agnostic framework. Attached to a frozen JEPA encoder, a lightweight MLP predicts a Gaussian action prior. At planning time, a closed-form Product-of-Gaussians update integrates this prior to guide sampling based on confidence. |
|
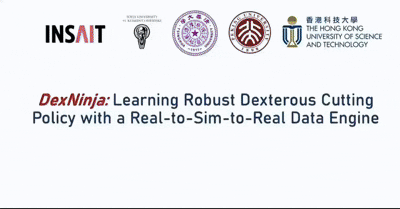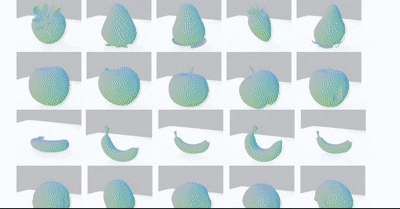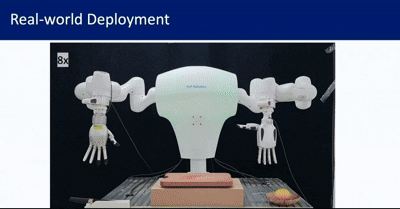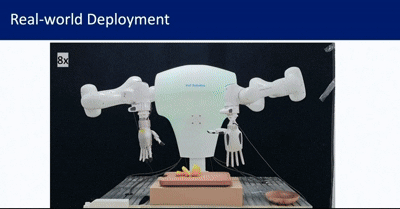
DexNinja: Learning Robust Dexterous Cutting Policy with a Real-to-Sim-to-Real Data Engine
Haozhe Lou*, Runyi Yang*, Wanqi Zhong, Caiyun Liu, Yicheng Liu, Wenhao Liu, Wenlong Ma, Jiawei Xia, Xu Zheng, Danda Pani Paudel†, Luc Van Gool†, Hang Zhao†, Yiming Li† 2026 Conference on Robot Learning (CoRL) & ICRA R2SR Workshop Spotlight [Paper] [Website] We introduce DexNinja, a Real2Sim2Real data engine for robust bimanual dexterous food cutting. DexNinja generates physically consistent data with deformable cutting simulation, and trains a stage-conditioned vision-tactile ACT policy with decoupled arm/hand actions and adaptive action chunking. |
|
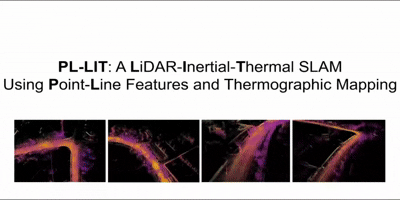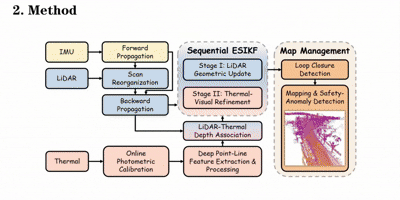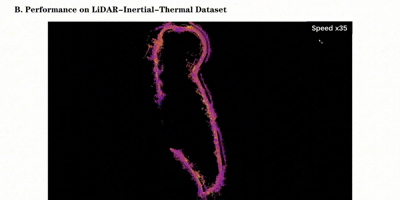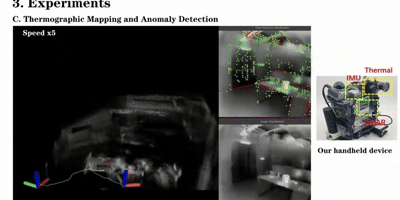
PL-LIT: A LiDAR-Inertial-Thermal SLAM system using Point-Line Features and Thermographic Mapping
Jiawei Xia, Yixiao Feng, Yongliang Shi†, Chao Gao, Renjing Xu, Weining Lu, Bin Liang† 2026 International Conference on Intelligent Robots and Systems (IROS) [Paper] [Video] We propose PL-LIT, a general LiDAR-Inertial-Thermal SLAM system. PL-LIT combines an online photometric calibration module with a deep neural network for point-line feature extraction. For state estimation, we design a tightly coupled LiDAR-Inertial-Thermal formulation within an Error-State Iterated Kalman Filter. In addition, PL-LIT builds a probabilistic thermal-intensity voxel map. |
|
CVIRO: A Consistent and Tightly-Coupled Visual-Inertial-Ranging Odometry on Lie Groups
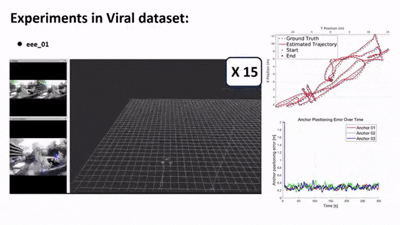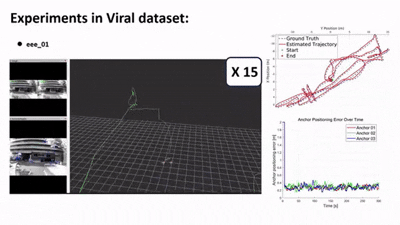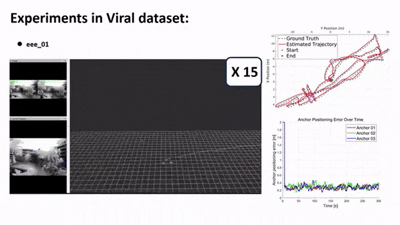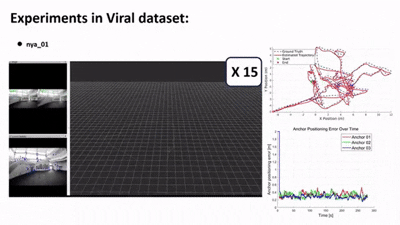
Yizhi Zhou, Ziwei Kang, Jiawei Xia, Xuan Wang† 2025 International Conference on Intelligent Robots and Systems (IROS) [Paper] [Video] This paper proposes a consistent and tightly-coupled visual-inertial-ranging odometry system based on the Lie group. |
|
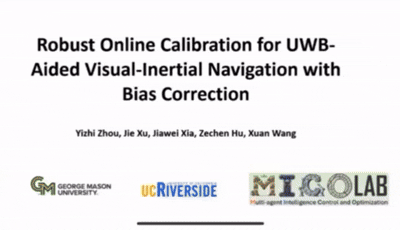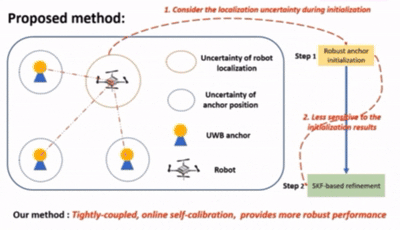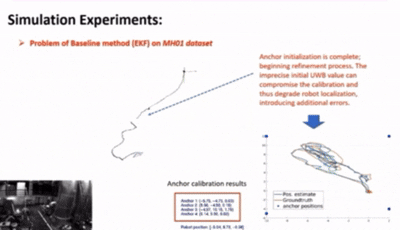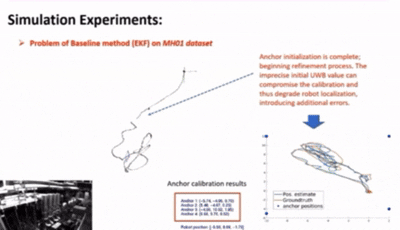
Robust Online Calibration for UWB-Aided Visual-Inertial Navigation with Bias Correction
Yizhi Zhou, Jie Xu, Jiawei Xia, Zechen Hu, Xuan Wang† 2025 International Conference on Intelligent Robots and Systems (IROS) [Paper] [Video] This paper proposes a robust online calibration method for UWB anchors in Visual-Inertial Navigation Systems. |
| Show more |
Research Projects |
|
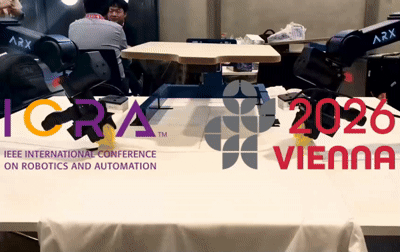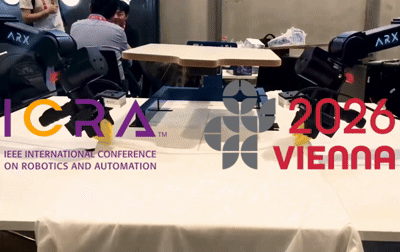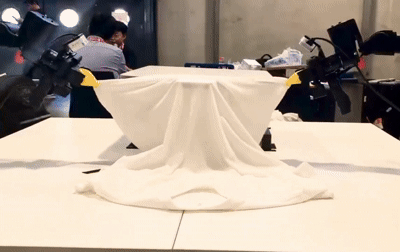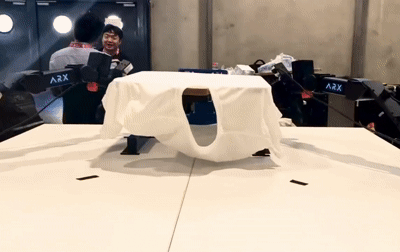
ICRA 2026 WBCD Competition Vienna Champion 🏆 (Track 4)
HCLab (HKUST-GZ) Our team won first place in the Flexible Manipulation Track at ICRA 2026 WBCD Challenge, held in Vienna, Austria. Our approach is based on fine-tuning a pre-trained vision-language-action (VLA) model with reinforcement learning. Ultimately, the model achieved a high success rate on the deformable/flexible clothing tasks. |
|
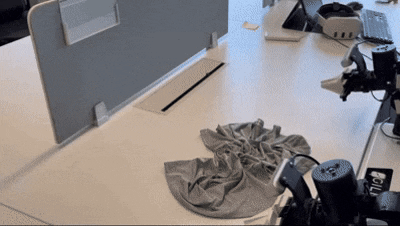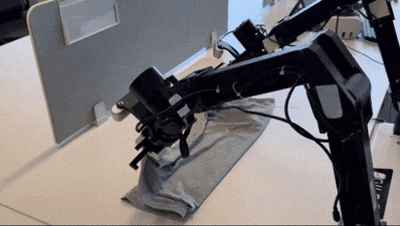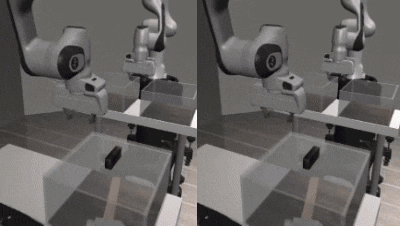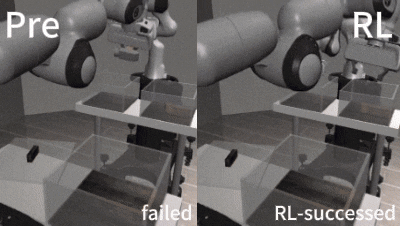
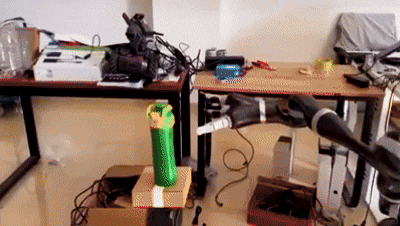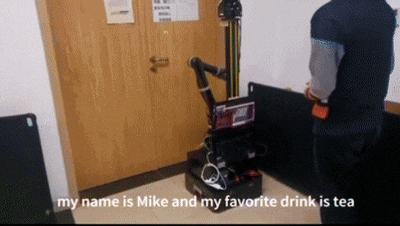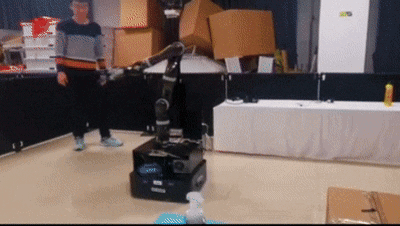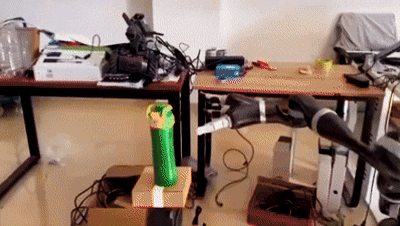
Reinforcement Learning Post-Training for Robotics Models
Jiawei Xia This project explored two approaches to post-training robotic models. First, we used the DAgger framework with positive and negative labels to post-train a VLA model. Second, we used sparse task-success rewards and an off-policy actor-critic framework to fine-tune a policy in simulation. |
|
RoboCup@Home: Development of an Intelligent Home Service Robot
Jiawei Xia, Xianglei Dong, Wengcong Zhang, Boyi Zhang, Yutong Sun Developed an intelligent home service robot using a Kinova Gen2 arm and an Azure Kinect camera on ROS Noetic, with functions including guest reception and guidance, voice interaction, object recognition, and room cleaning. Used Gemini, SAM2, and GraspNet to estimate object pose and grasp objects. Controlled the arm using Actionlib and MoveIt. Applied FAST-LIO2 with Livox MID-360 for indoor mapping and localization. |
|
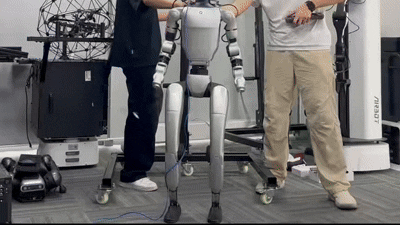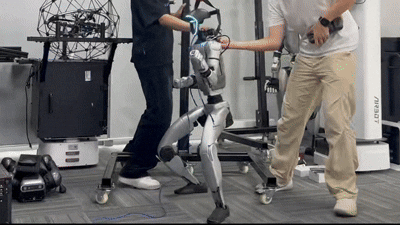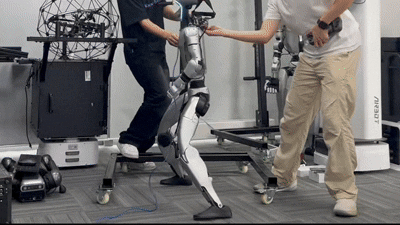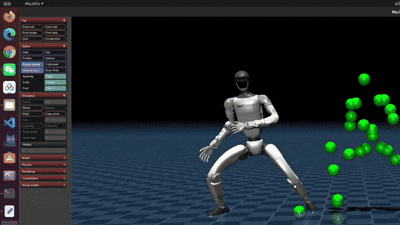
Training Unitree G1 to Imitate Kung Fu Behaviors
Yixiao Feng, Jiawei Xia Building on KungfuBot, we used inverse kinematics retargeting and reinforcement learning to enable humanoid robots to imitate highly dynamic behaviors (e.g., kungfu, dancing). Developed sim2sim in MuJoCo and sim2real with Unitree SDK, successfully deploying the framework on the Unitree G1 robot. |
|
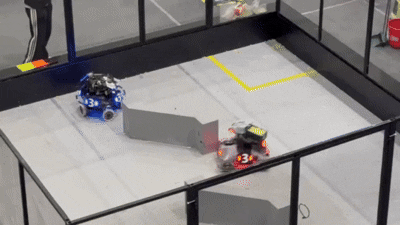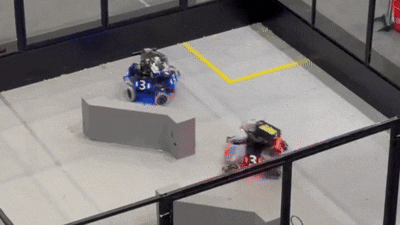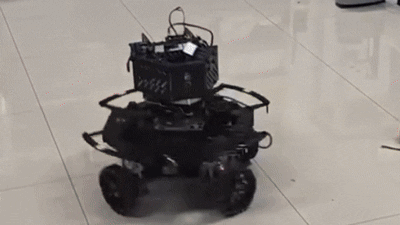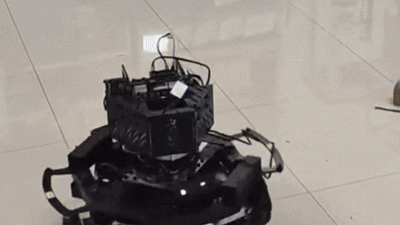
RoboMaster University League 1v1 Combat Competition
Yutao Guo*, Hanhong Fu*, Jiawei Xia Used PnP to calculate the 3D position of the armor plate, and used Kalman filtering for tracking. The robot used four M3508 motors for the chassis and two M6020 motors for the turret, controlled via CAN communication and PID algorithms for current, speed, and position loops. Used feedforward PID to improve the gimbal drive and achieve gravity compensation. |
|
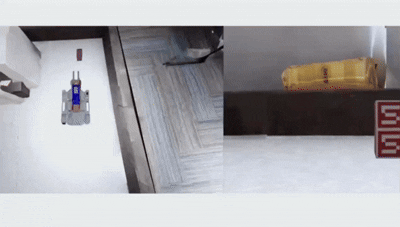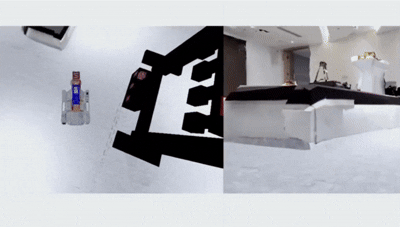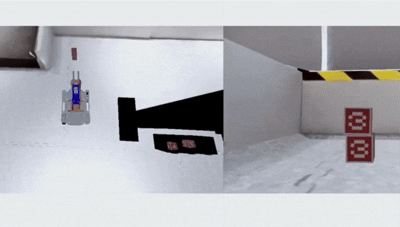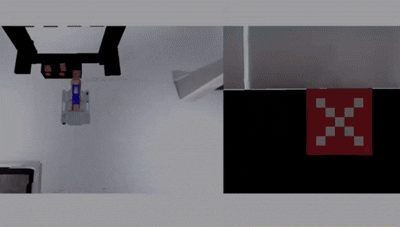
Simulation of an Intelligent Mineral Handling Robot
Xianglei Dong*, Jiawei Xia*, Wencong Zhang, Boyi Zhang ICRA 2024 RoboMaster Sim2real Challenge: In the organizers' Docker-based Habitat-Sim environment, we used ArUco markers and solvePnP to estimate box poses. We deployed an extended Kalman filter with an omnidirectional motion model for state estimation, using IMU data, odometry, and laser scans converted from depth images. |
| Show more |
Honours & Awards |
|
| Show more |
Leadership & Activities |
|
| Show more |
|
Website template adapted from here. |